- Published on
Beyond the Gala: OmniXtreme Breaks the Generality Barrier for Humanoid Agility
One tap, and our reporting appears more often in your Google Top Stories. It makes a real difference to a small newsroom.
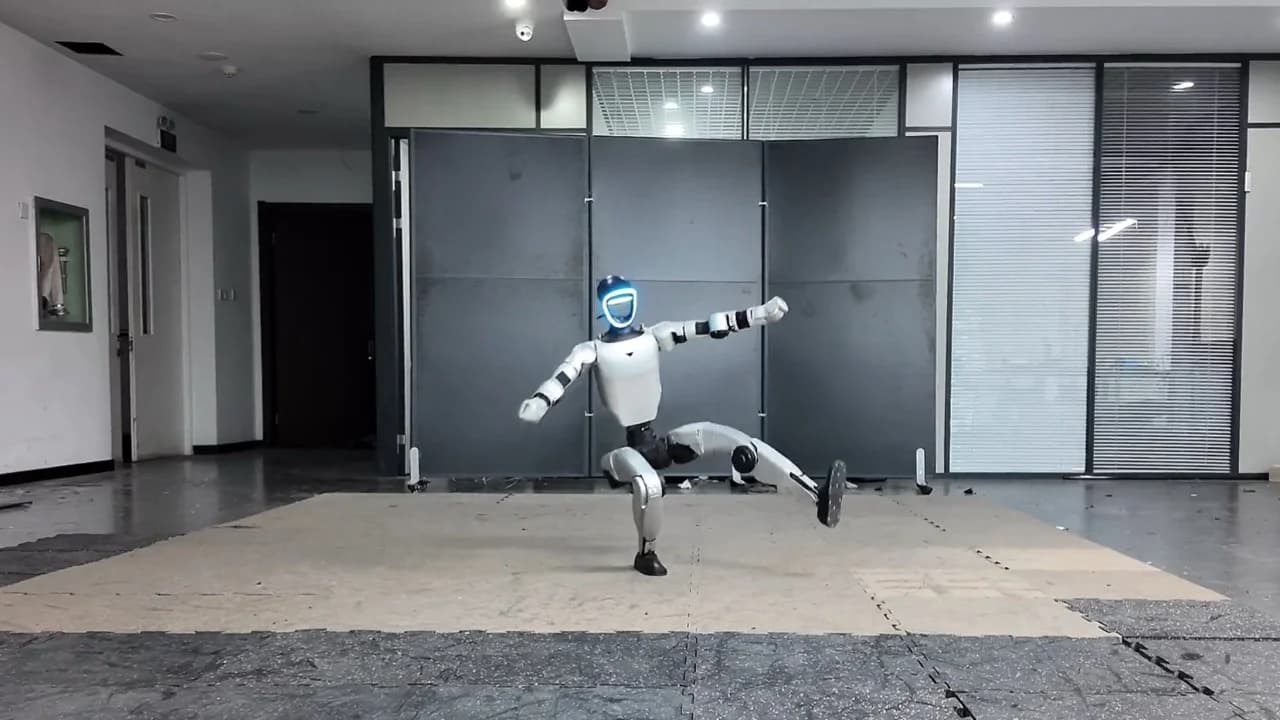
The flashy martial arts routine that captivated audiences at the 2026 Spring Festival Gala may have been a milestone for public interest, but for the researchers behind the hardware, it highlighted a persistent technical limitation. As Siyuan Huang, a research scientist at the Beijing Institute for General Artificial Intelligence (BIGAI), noted on X, many of the high-dynamic motions seen on stage are the result of "overfitted tracking policies"—controllers fine-tuned for a single specific sequence rather than a general capability.
To address this, BIGAI and Unitree Robotics have introduced OmniXtreme, a scalable framework that allows a single, unified policy to execute a diverse library of extreme behaviors. The system enables a Unitree G1 robot to seamlessly transition between backflips, acrobatic rolls, and complex breakdancing maneuvers without the performance collapse typically seen when scaling motion libraries.
Cracking the "Generality Barrier"
In humanoid robotics, there is a long-standing trade-off between fidelity and scalability. As the library of reference motions grows more diverse, traditional reinforcement learning (RL) policies often struggle with "gradient interference," leading to "average" or conservative movements that fail during high-dynamic execution.
OmniXtreme overcomes this by identifying and decoupling two distinct bottlenecks: the learning bottleneck in simulation and the physical executability bottleneck on hardware.
Stay ahead in humanoid robotics
One email a week: the launches, funding and research that mattered. Join the researchers, founders and technologists following the field.
Stage 1: Scalable Flow-based Pre-training
The first stage replaces standard MLP-based RL with a high-capacity flow-matching policy. By using a specialist-to-unified distillation process, the researchers "trained" the unified policy to imitate a collection of individual motion experts. This generative approach allows the model to capture a vast range of heterogeneous behaviors without the optimization interference that plagues from-scratch RL.
Stage 2: Actuation-Aware Post-training
While the flow-based policy provides the "brain" for movement, real-world physics remains the ultimate "litmus test". High-dynamic motions often push actuators to their limits, triggering unmodeled nonlinearities like torque-speed losses or overcurrent protection.
OmniXtreme introduces a residual reinforcement learning phase. Instead of relearning the motion, a lightweight MLP policy is trained to produce corrective actions that account for realistic hardware constraints, including torque-speed limits and power-safety regularization. This refinement ensures that a backflip that works in simulation remains physically executable on a real G1 robot.
Performance and Real-World Limits
The results of this two-stage approach are strikingly consistent. In 157 real-world trials, OmniXtreme achieved high success rates across a variety of skill categories:
| Skill Category | Number of Motions | Success Rate (%) |
|---|---|---|
| Flip | 7 | 96.36% |
| Martial Arts | 3 | 93.33% |
| Handspring | 5 | 88.57% |
| Breakdance | 5 | 86.36% |
| Acrobatics | 4 | 80.00% |
The team reported that enforcing actuator torque-speed constraints was sufficient for impulsive motions like flips. However, more complex "contact-rich" skills, such as breakdancing, required aggressive domain randomization and power-safety penalties to survive the high braking loads and energy absorption during impact.
The Road to Universal Control
OmniXtreme enters an increasingly crowded field of high-scale humanoid control research. It follows NVIDIA's SONIC, which also aims for universal whole-body tracking , and Amazon's OmniRetarget and PHP framework, which focus on physical interactions and agile traversal.
Despite the success, the researchers acknowledge that the "reality gap" is not fully closed. Failures still occur during highly impulsive landings where transient loads trigger battery undervoltage or motor overcurrent events—factors often missing from current simulators.
As China moves toward a national standard system for humanoid robotics, the "showmanship" of backflips is becoming a proving ground for the stability required for future industrial labor. By releasing the model checkpoints, the BIGAI and Unitree team is inviting the community to push these "robot gymnasts" even further.
Share this article
Read next
- Published on
- Reading time
- 4 min read
HumanX: The AI Framework Turning Unitree’s G1 into a Basketball Pro
- Published on
- Reading time
- 4 min read
China’s Universities Launch "Embodied Intelligence" Majors to Feed a Hungry Robot Workforce
- Published on
- Reading time
- 4 min read
Don’t Forget the Salt: Physical Intelligence Equips Robots with 15-Minute "Multi-Scale" Memory
- Published on
- Reading time
- 3 min read
NVIDIA "Supersizes" Humanoid Control: SONIC Open-Sources Whole-Body Tracking at Scale
- Published on
- Reading time
- 4 min read
Beyond the VLA: NVIDIA’s DreamZero and the ‘GPT-2 Moment’ for Robotic World Models
- Published on
- Reading time
- 4 min read
NVIDIA’s "DoorMan" Teaches Humanoids to Open Doors Faster Than Humans Can

Stay ahead in humanoid robotics
One email a week: the launches, funding and research that mattered. Join the researchers, founders and technologists following the field.