LiberAI
Beijing physical AI startup founded in December 2025 that trains world action models on human experience captured with its own data gloves, for dexterous-hand robots in the home.
- Founded
- 2025
- Headquarters
- BeijingChina
- Employees
- 130
- Total funding
- $139M
- Our coverage
- 1stories
LiberAI is a Beijing physical AI company that trains robot foundation models on recorded human experience rather than on large fleets of teleoperated robots. Songming Liu, a Tsinghua University PhD candidate, founded it in December 2025 with co-founder Fanqi Lin. By October 2026 it employed more than 130 people. Alongside the models, the company builds its own data-collection gloves and a robot platform designed to resemble the humans it learns from.
Founders
Liu studied under Professor Jun Zhu at Tsinghua and moved from AI for physics into embodied AI during his doctorate. Before LiberAI he led the RDT series of robot foundation models: RDT-1B, released in October 2024, which paired large-scale pretraining with a diffusion transformer, and RDT-2 in September 2025, pretrained on human data gathered with UMI handheld grippers rather than robots. Lin is a PhD student at Tsinghua's Institute for Interdisciplinary Information Sciences, advised by Professor Yang Gao. His work includes the Data Scaling Laws paper on robot imitation learning, an ICLR 2025 oral, and a stint with Toyota Research Institute's Large Behavior Models team.
The bet: dexterous hands and human data
Most of the industry starts with one-degree-of-freedom grippers, because they produce working demos quickly. LiberAI went straight to multi-fingered hands: the hand it deploys has 20 degrees of freedom. Liu's argument is that human video and human hand recordings line up naturally with a five-fingered hand and never with a gripper, so a model trained this way should transfer down to grippers far more easily than a gripper model scales up to hands.
That choice also decides how the company collects data. Teleoperation, UMI grippers and exoskeletons ask a person to move like a robot. LiberAI's gloves do the opposite and try to stay unnoticed, so people move as they normally would. The gloves record hand poses and trajectories during everyday manipulation. Paired with first-person and wrist-mounted cameras, those recordings give the model action labels that ordinary video lacks. LiberAI said in July 2026 that the gloves had entered mass production. They do not yet capture touch or force, which the company lists as future work alongside collection in a wider range of real homes.
Liber-0
Four months after it was founded, LiberAI released its first foundation model for high-degree-of-freedom dexterous manipulation. Its main model line is Liber-0, a world action model that predicts future video frames together with the actions that produce them. The company says Liber-0 was pretrained on more than 2.2 million hours of human experience, mixing broad human video with glove and robot recordings. On 17 September 2026 it released Liber-0 Preview, which placed first on the RoboDojo leaderboard at launch: an average score of 30.74 and an average success rate of 25.52% across 42 tasks. That was the day after GPT-6 Astra posted its robotics results, and LiberAI's announcement placed Astra third.
Funding
LiberAI announced four funding rounds in five months. In May 2026 it disclosed seed, angel and angel+ rounds totalling nearly RMB 500 million, backed by ZhenFund, HongShan, Meituan Long-Z and Shunwei Capital. ZhenFund had funded the seed round alone in 2025. Shunwei led a Pre-A round in June, followed by a Pre-A+ round in July and a Pre-A++ round in September. Each was described only as several hundred million yuan, and by September cumulative funding had passed RMB 1 billion.
Funding
$139M raised| Round | Date | Amount | Valuation | Lead investors |
|---|---|---|---|---|
| Pre-A | September 2026 | Undisclosed | — | — |
| Pre-A | July 2026 | Undisclosed | — | — |
| Pre-A | June 2026 | Undisclosed | — | Shunwei Capital |
| Seed | May 2026 | $69M | — | — |
Timeline
Unveils Liber-0 world action model for zero-shot manipulation
The model, pretrained on over 2.2 million hours of human experience including glove-recorded demonstrations, scored 36.0% overall success across 600 trials on 60 GPT-6-proposed tasks without task-specific robot demonstrations.
LiberAI Unveils Liber-0: Learning from Human Experience for Zero-Shot Robot ManipulationLiber-0 Preview tops the RoboDojo leaderboard
The preview of its world action model places first on RoboDojo at launch, with a 30.74 average score across 42 tasks. A Pre-A++ round takes cumulative funding past RMB 1 billion the same day.
mp.weixin.qq.com ↗Pre-A+ round; data gloves enter mass production
A further round of several hundred million yuan from investors including Sinovation Ventures and CMC Capital, as LiberAI says its human-data gloves have entered mass production.
mp.weixin.qq.com ↗Shunwei Capital leads Pre-A round
A round of several hundred million yuan, with existing investors HongShan and ZhenFund adding more.
mp.weixin.qq.com ↗Seed, angel and angel+ rounds total nearly RMB 500 million
ZhenFund, HongShan, Meituan Long-Z and Shunwei Capital back the company across three early rounds.
mp.weixin.qq.com ↗First dexterous-manipulation foundation model
Four months after founding, LiberAI releases its first foundation model for high-degree-of-freedom robot hands.
mp.weixin.qq.com ↗LiberAI founded in Beijing
Songming Liu, a Tsinghua PhD candidate who led the RDT robot foundation models, starts the company with co-founder Fanqi Lin.
mp.weixin.qq.com ↗
Latest on LiberAI
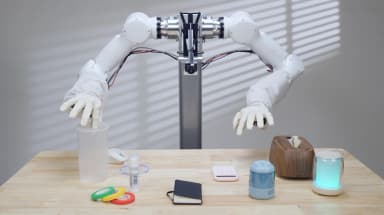
LiberAI Unveils Liber-0: Learning from Human Experience for Zero-Shot Robot Manipulation
LiberAI's Liber-0 world action model learns from more than 2.2 million hours of human experience and reached 36.0% success on 60 GPT-6-proposed tasks without task-specific robot demonstrations.
Sources
- 00 后清华特奖得主完成数亿元融资 (Pre-A announcement, 11 Jun 2026)· checked November 2, 2026
- Pre-A++ announcement, 17 Sep 2026: cumulative funding over RMB 1 billion, converted at ~7.2· checked November 2, 2026