- Published on
- Reading time
- 4 min read
NVIDIA Details Open-Source GR00T N1 Foundation Model and Hover Controller for Humanoids
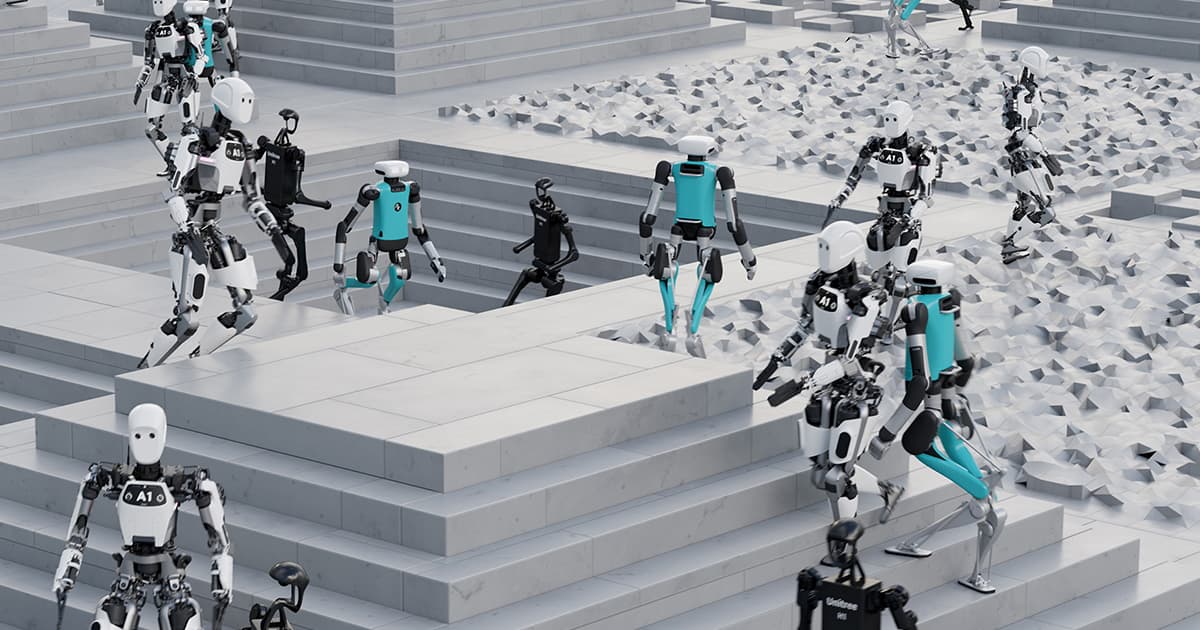
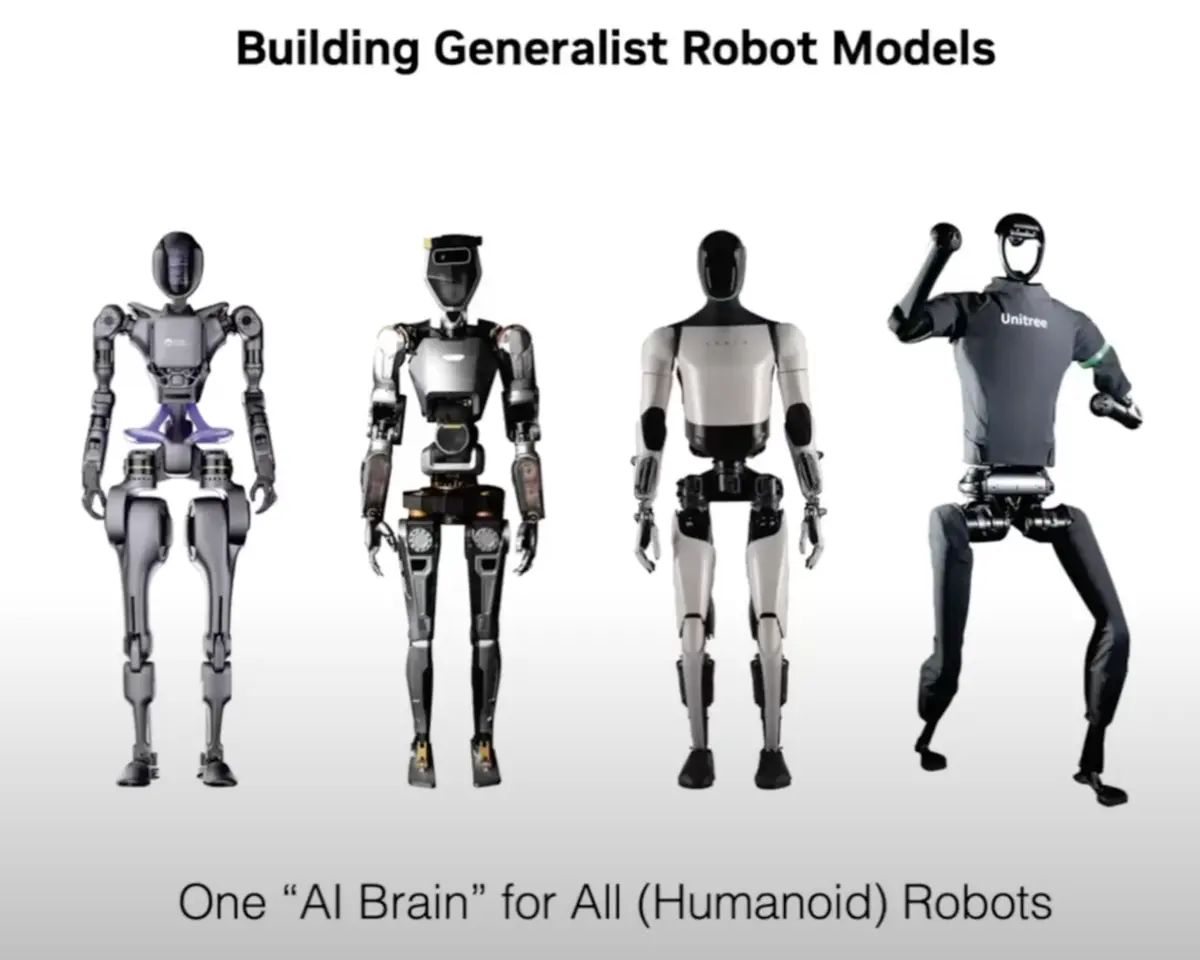
NVIDIA Research Scientist Yuke Zhu presented Project GR00T at Marktechpost miniCON Open Source AI 2025, detailing the company's simulation-first approach to building generalist foundation models for humanoid robots. Key releases include the open-source GR00T N1 multimodal model and the Hover whole-body controller, designed to enable cross-embodiment capabilities and accelerate development for robotics partners.