- Published on
UK Team Secures £5M to Advance Human-Like Robot Dexterity with AI Co-Design
One tap, and our reporting appears more often in your Google Top Stories. It makes a real difference to a small newsroom.
Your guide
Rich Robinson
Jee Chee Ren · Executive tour
See China’s AI and robotics ecosystem first-hand.
Six days exploring AI, robotics and advanced manufacturing.
With Rich Robinson, Clinical Professor of Entrepreneurship at Peking University
Beijing · Guangzhou · Shenzhen
29 November–4 December 2026
Referral partnership · We earn a commission on referred bookings.
UK Team Secures £5M to Advance Human-Like Robot Dexterity with AI Co-Design
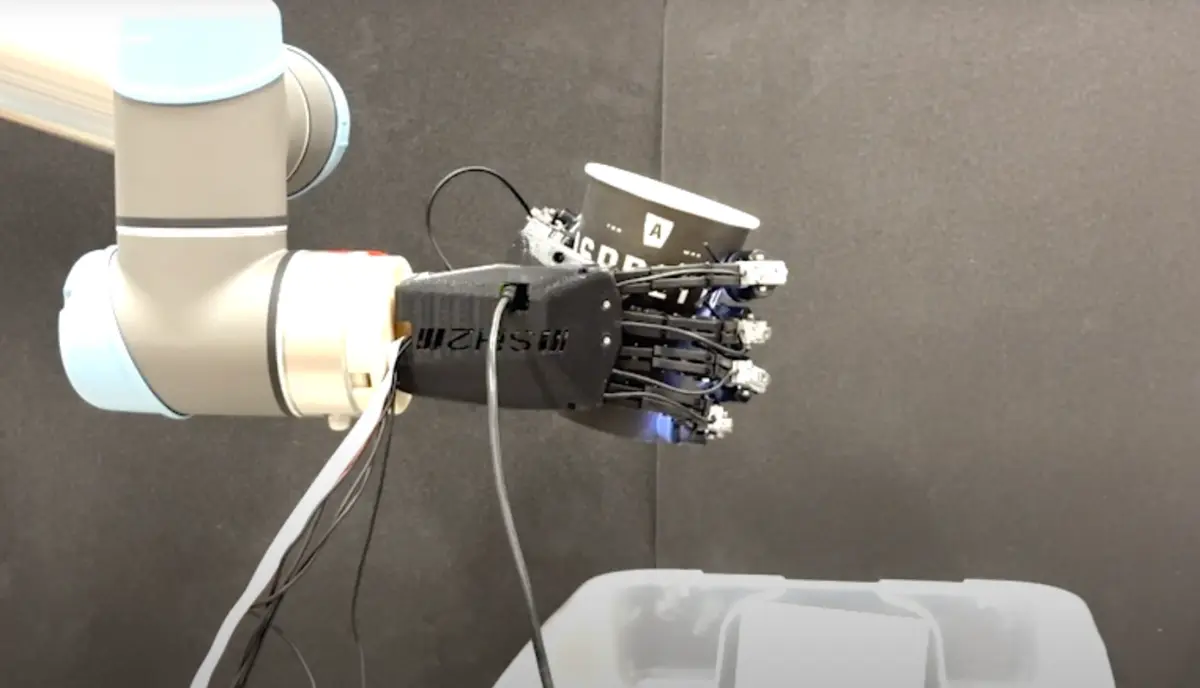
A research team from the University of Bristol and Imperial College London has been awarded a £5 million grant from the Advanced Research + Invention Agency (ARIA) to develop robotic hands capable of human-like dexterity. The project aims to leverage artificial intelligence to co-design both the physical robotic hands and their intelligent control systems, optimizing them for complex manipulation tasks.
Addressing the Dexterity Gap
This initiative, titled 'Democratising Co-Design of Hardware and Control for Robot Dexterity,' is a significant part of ARIA's wider £57 million Robot Dexterity program. ARIA's program seeks to bridge the current gap between rapid advancements in AI and the slower development of robotic physical capabilities. As noted by ARIA, while AI is transforming what robots can think, their ability to do—particularly tasks requiring fine motor skills—lags behind human capabilities, limiting their application in many critical areas.
The project is led by Professor Nathan Lepora at the University of Bristol, known for his work in tactile robotics, and Dr. Ed Johns at Imperial College London, an expert in AI for robot learning. Their collaboration intends to tackle a fundamental challenge: current methods for designing robots for specific tasks are often manual and do not guarantee optimal performance.
An Evolutionary Approach to Robot Design
Inspired by evolutionary biology, the team plans to develop software that allows users to specify a task and its constraints. The system will then automatically generate and optimize novel manipulator designs along with their controllers. This approach aims to democratize the creation of robotic solutions, enabling users to easily design hardware and control systems tailored to their specific needs.
The weekly humanoid robotics briefing
One email a week: the launches, funding and research that mattered, with context from Humanoids Daily.
Read recent issues“Robust manipulation with robotic hands would have revolutionary implications for industry and society, and is the key bottleneck in practical humanoid robots,”
"Robust manipulation with robotic hands would have revolutionary implications for industry and society, and is the key bottleneck in practical humanoid robots," said Professor Lepora. He highlighted that the project will combine Bristol's expertise in rapidly creating dexterous robot hands with Imperial's proficiency in robot learning for highly dexterous tasks.
Professor Lepora's previous work at the University of Bristol includes the development of a four-fingered robotic hand with 3D-printed tactile fingertips that can rotate objects in any direction, even when upside down—a feat known as 'AnyRotate.' This technology, which mimics the internal structure of human skin using tiny cameras within the fingertips, demonstrates the team's existing capabilities in creating sensor-rich hardware.
Paving the Way for Practical Applications
The £5 million funding will facilitate the creation of a 3D-printable robot platform for rapid prototyping and a center for large-scale real-world testing of these next-generation robotic hands. The overarching goal is to produce co-designable dexterous robot hands with intelligent control systems that bring robotic manipulation closer to human capabilities.
Success in this endeavor could significantly impact industries reliant on manual labor, from manufacturing and logistics to waste sorting and potentially even healthcare support, aligning with ARIA's objective to ease labor shortages and boost productivity through more capable machines. The project also underscores a growing trend towards integrating sophisticated tactile sensing into robotic systems, a development deemed crucial for achieving more human-like interaction with the physical world.
Share this article
Read next
- Published on
- Reading time
- 4 min read
Eka Robotics Raises $150 Million to Give Robots a Better Feel for the Physical World
- Published on
- Reading time
- 4 min read
Former Boston Dynamics Roboticist Unveils Voxel, a $20,000 Home-Tidying Robot
- Published on
- Reading time
- 2 min read
This Week’s Newsletter: Gemini 4 Meets Apollo, PI Opens Its API and Robots Get to Work
- Published on
- Reading time
- 3 min read
After Its Stock Surge, Unitree Warns Humanoid Commercialization Is Still in Its Early Days
- Published on
- Reading time
- 3 min read
Schaeffler Puts Humanoids to Work Building Parts for Other Humanoids
- Published on
- Reading time
- 2 min read
AGCO Signs Agility Deal to Bring Humanoid Robots to Its Kansas Factory
The weekly humanoid robotics briefing
One email a week: the launches, funding and research that mattered, with context from Humanoids Daily.
Read recent issues