- Published on
- Reading time
- 4 min read
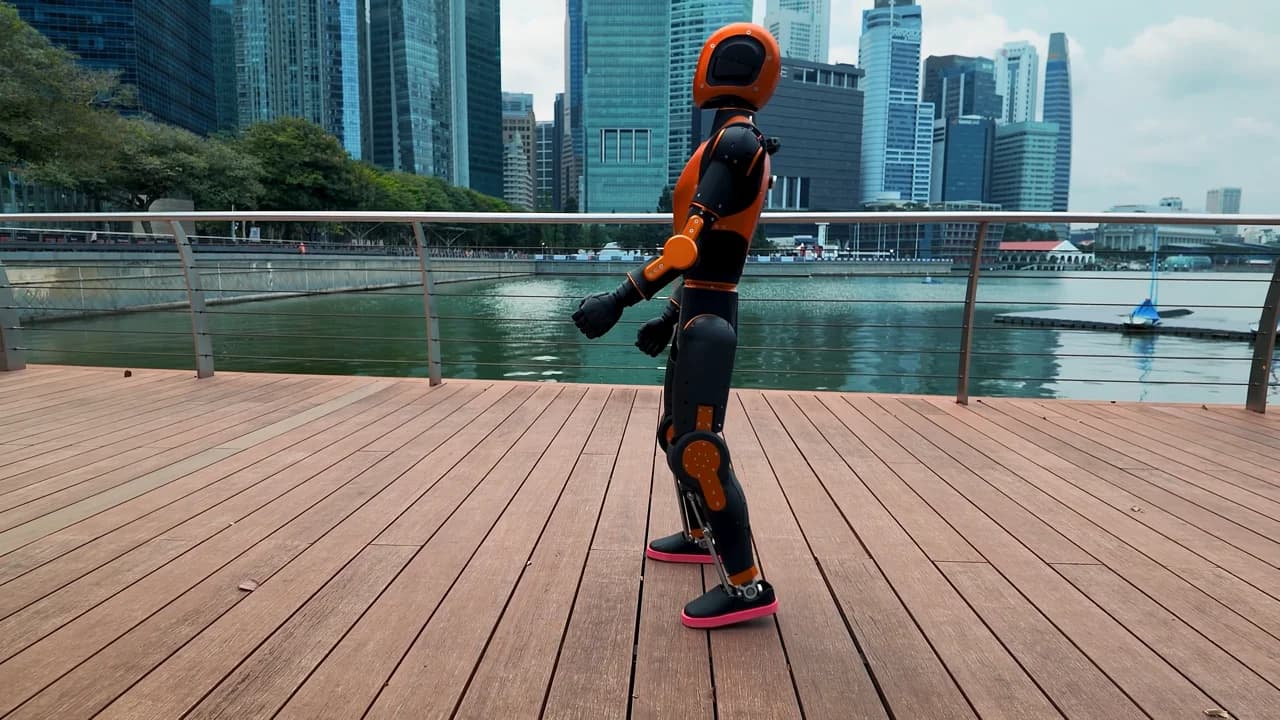
Asimov Open-Sources the Training Code Behind Its Humanoid’s Walk
The Asimov 1 release exposes locomotion rewards, actuator settings and simulation training code, giving developers tools to adapt the walking controller for the open-source humanoid.