- Published on
Figure Is Introducing Learned Natural Walking
One tap, and our reporting appears more often in your Google Top Stories. It makes a real difference to a small newsroom.
Your guide
Rich Robinson
Jee Chee Ren · Executive tour
See China’s AI and robotics ecosystem first-hand.
Six days exploring AI, robotics and advanced manufacturing.
With Rich Robinson, Clinical Professor of Entrepreneurship at Peking University
Beijing · Guangzhou · Shenzhen
29 November–4 December 2026
Referral partnership · We earn a commission on referred bookings.
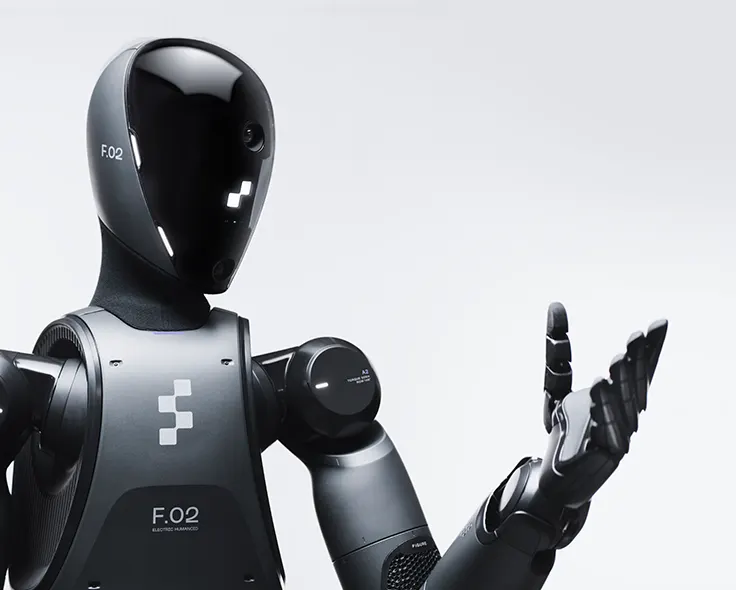
Bridging the Sim-to-Real Gap: A New Era in Humanoid Robotics
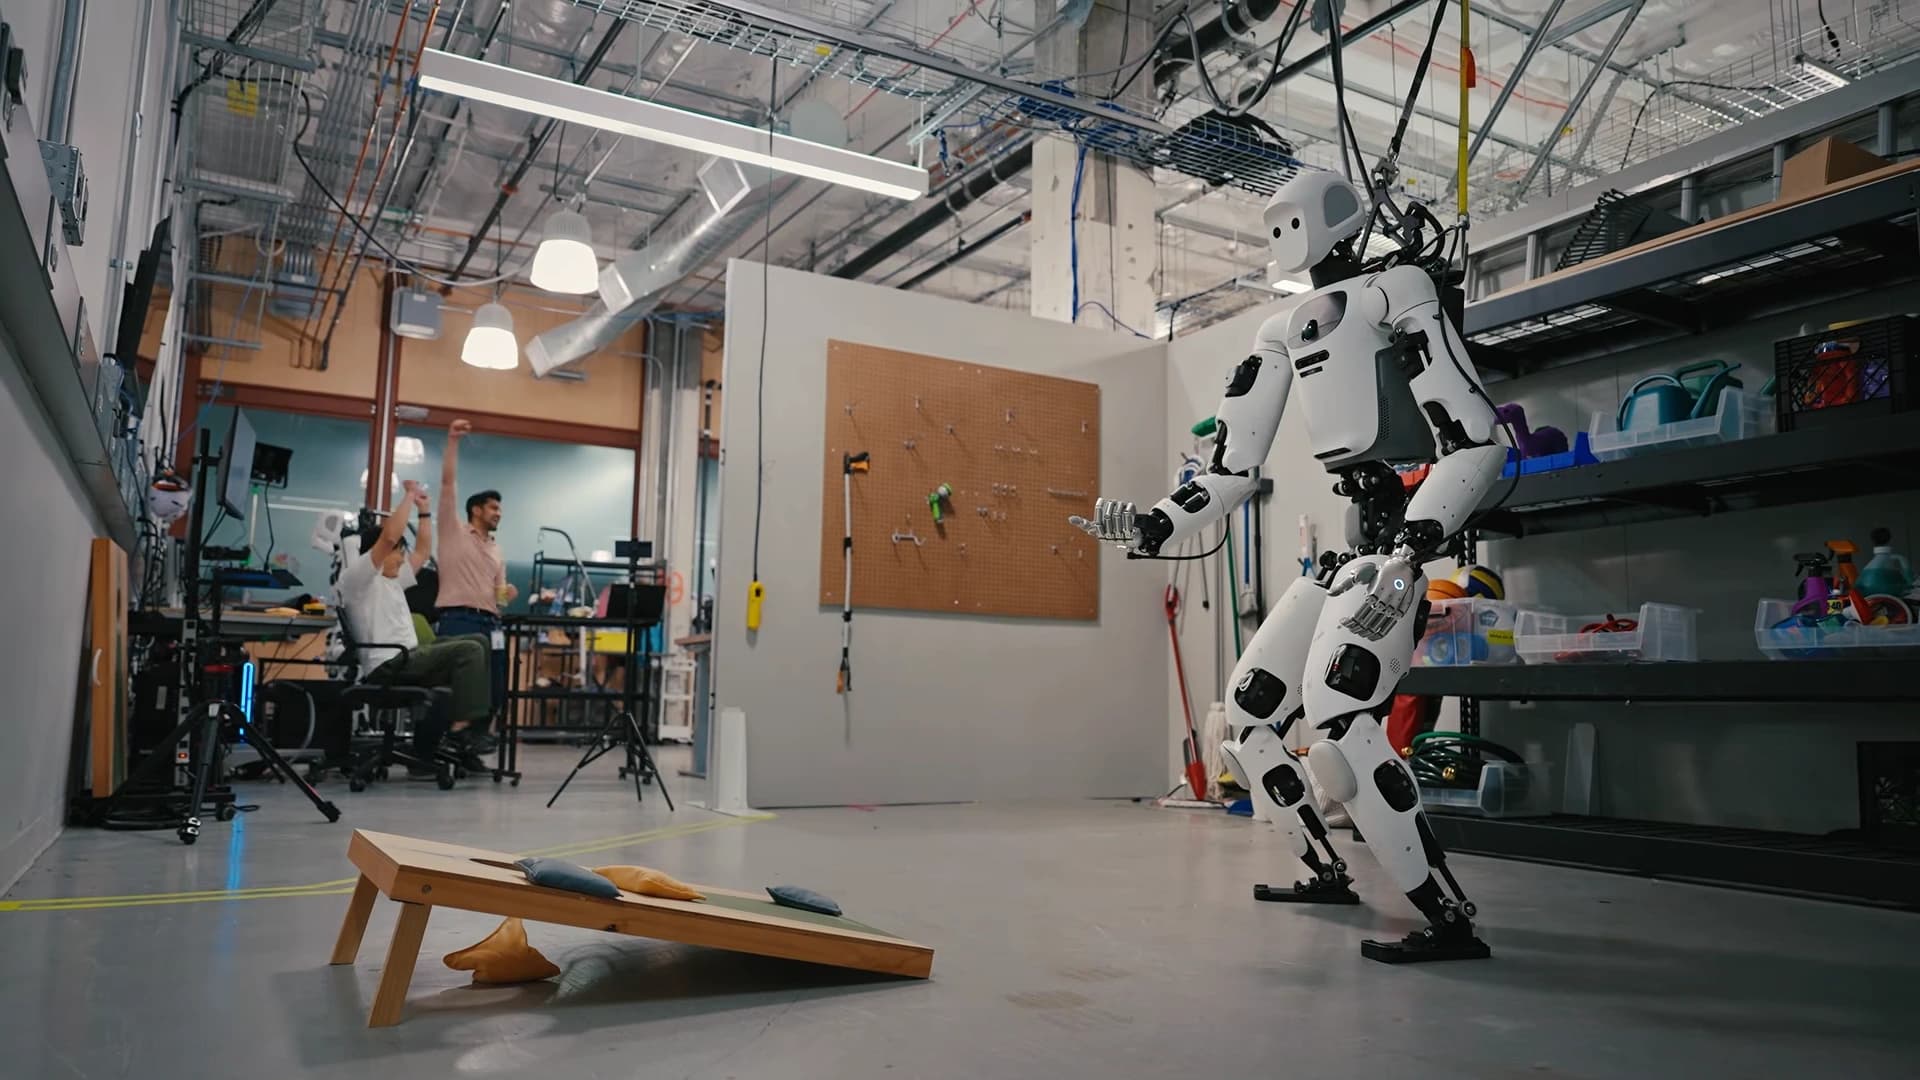
The landscape of humanoid robotics is undergoing rapid change, propelled by advancements in reinforcement learning (RL). A groundbreaking end-to-end neural network developed by Figure is setting new standards in humanoid locomotion, utilizing RL to achieve human-like walking in their Figure 02 robot. This innovation promises significant strides, yet it also raises important questions about the scalability and robustness of these technologies.
Leveraging Simulation for Human-Like Movement
At the core of Figure's approach is the application of RL within high-fidelity physics simulations. By running thousands of virtual robots under varied conditions, the team effectively simulates years' worth of data within mere hours. This method allows the RL controller to develop a robust, transferable policy for walking, bringing human-like gait, heel-strike, and arm-leg synchronization into the robotic realm.
The reliance on simulations addresses a critical bottleneck: real-world testing can be time-consuming and resource-intensive. By contrast, simulations offer a cost-effective, rapid alternative, albeit with the recognition that they are approximations of reality. Notably, Figure's simulations incorporate diverse scenarios, from varying terrains to mechanical disturbances, ensuring a well-rounded training process.
The weekly humanoid robotics briefing
One email a week: the launches, funding and research that mattered, with context from Humanoids Daily.
Read recent issuesSim-to-Real Transfer: Addressing the Gap
Transferring learned behavior from simulations to real-world robots—known as the "sim-to-real gap"—presents notable challenges. Figure tackles this through domain randomization, wherein physical parameters are varied extensively in simulations, helping the policy to generalize better when tested on actual hardware. Moreover, the use of high-frequency torque feedback enhances the real-world application by accounting for discrepancies in actuator dynamics.
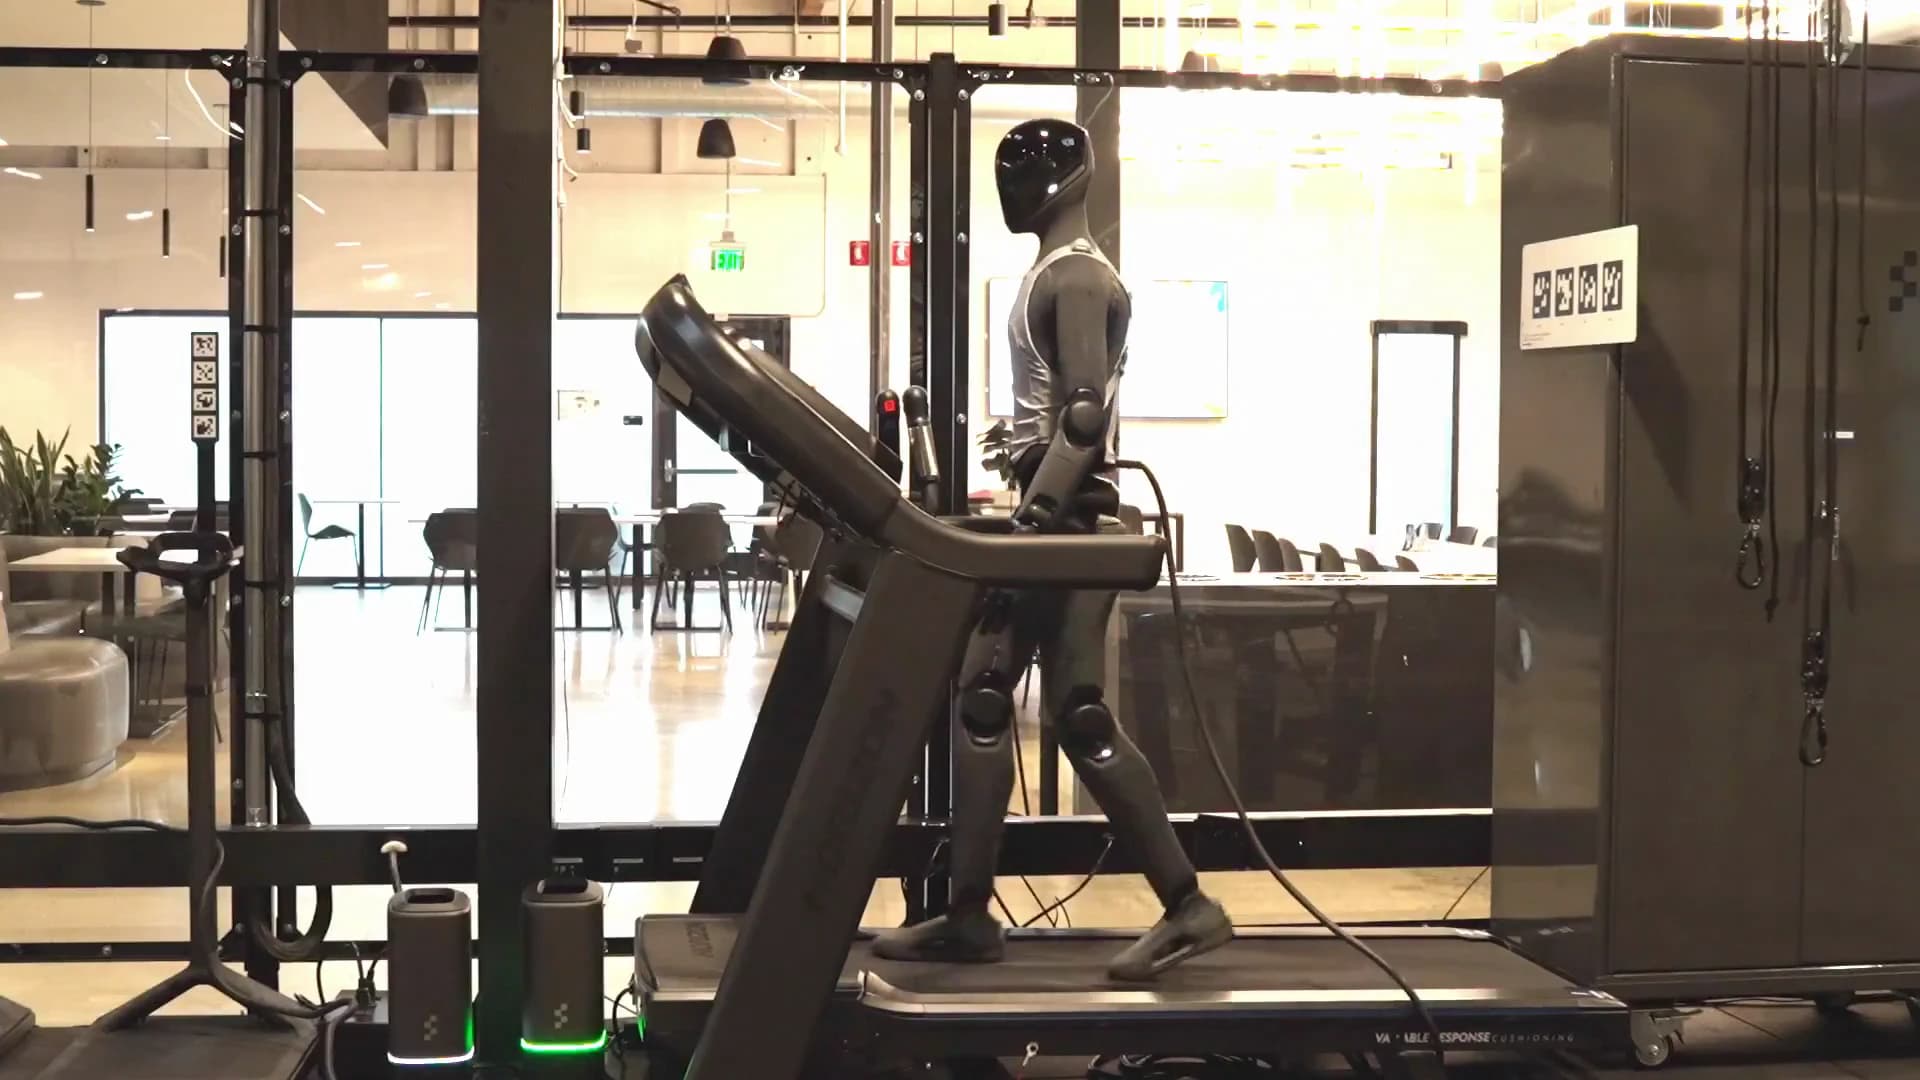
This methodology has shown promising results, evidenced by consistent human-like walking across a fleet of Figure 02 robots. The potential for zero-shot transfer without additional tuning underscores the robustness and adaptability of the developed policy.
Engineering Challenges and Future Prospects
Despite the encouraging results, Figure acknowledges the inherent complexities in achieving truly human-like locomotion. While the robots emulate human gait closely, further refinement is necessary to capture subtler elements of human movement. Moreover, as the fleet size scales, ensuring consistency and efficiency without manual intervention will be paramount.
The scalability of this technology to thousands or even millions of humanoid robots presents both an opportunity and a challenge. Successfully deploying such systems could revolutionize sectors reliant on humanoid robotics, including logistics, healthcare, and domestic assistance.
Conclusion
Figure's work represents a significant leap forward in humanoid robotics, illustrating the potential of RL and high-fidelity simulations in solving complex locomotion problems. Yet, several challenges remain—especially in terms of scaling and optimizing behavior in highly dynamic environments.
Share this article
Read next
- Published on
- Reading time
- 4 min read
The Last Millimeter: Physical Intelligence Unveils RL Tokens for Hyper-Fast Precision
- Published on
- Reading time
- 2 min read
Figure’s Humanoid Has Walked 348 Miles on a Treadmill—and It’s Still Going
- Published on
- Reading time
- 3 min read
Nvidia Has Discussed Another $1 Billion Investment in Figure, The Information Reports
- Published on
- Reading time
- 5 min read
Figure Melts Figure 02 With Arnold Schwarzenegger in a Terminator-Style Sendoff
- Published on
- Reading time
- 4 min read
Figure’s Multibillion-Dollar Compute Deal Meets Nscale’s Data-Center Buildout Challenge
- Published on
- Reading time
- 3 min read
Hasta La Vista, Figure 02: Adcock Teases a Terminator-Style Sendoff
The weekly humanoid robotics briefing
One email a week: the launches, funding and research that mattered, with context from Humanoids Daily.
Read recent issues