- Published on
Brett Adcock Says Humanoids Will Need More Data and Compute Than LLMs
One tap, and our reporting appears more often in your Google Top Stories. It makes a real difference to a small newsroom.
Supported by RoboStrategySupport for Humanoids Daily comes from RoboStrategy
Sponsored
Investing involves risk, including possible loss of principal. Read the prospectus before investing.
- Brett Adcock predicts humanoids will ultimately need more data and compute than large language models.
- Sharing Humanoids Daily’s interview clip, the Figure CEO said scaling robot intelligence and manufacturing would eventually require hundreds of billions of dollars.
- The post expands on his four-stage roadmap. It is an investment thesis, not a new funding announcement or proof that general-purpose robotics has been solved.
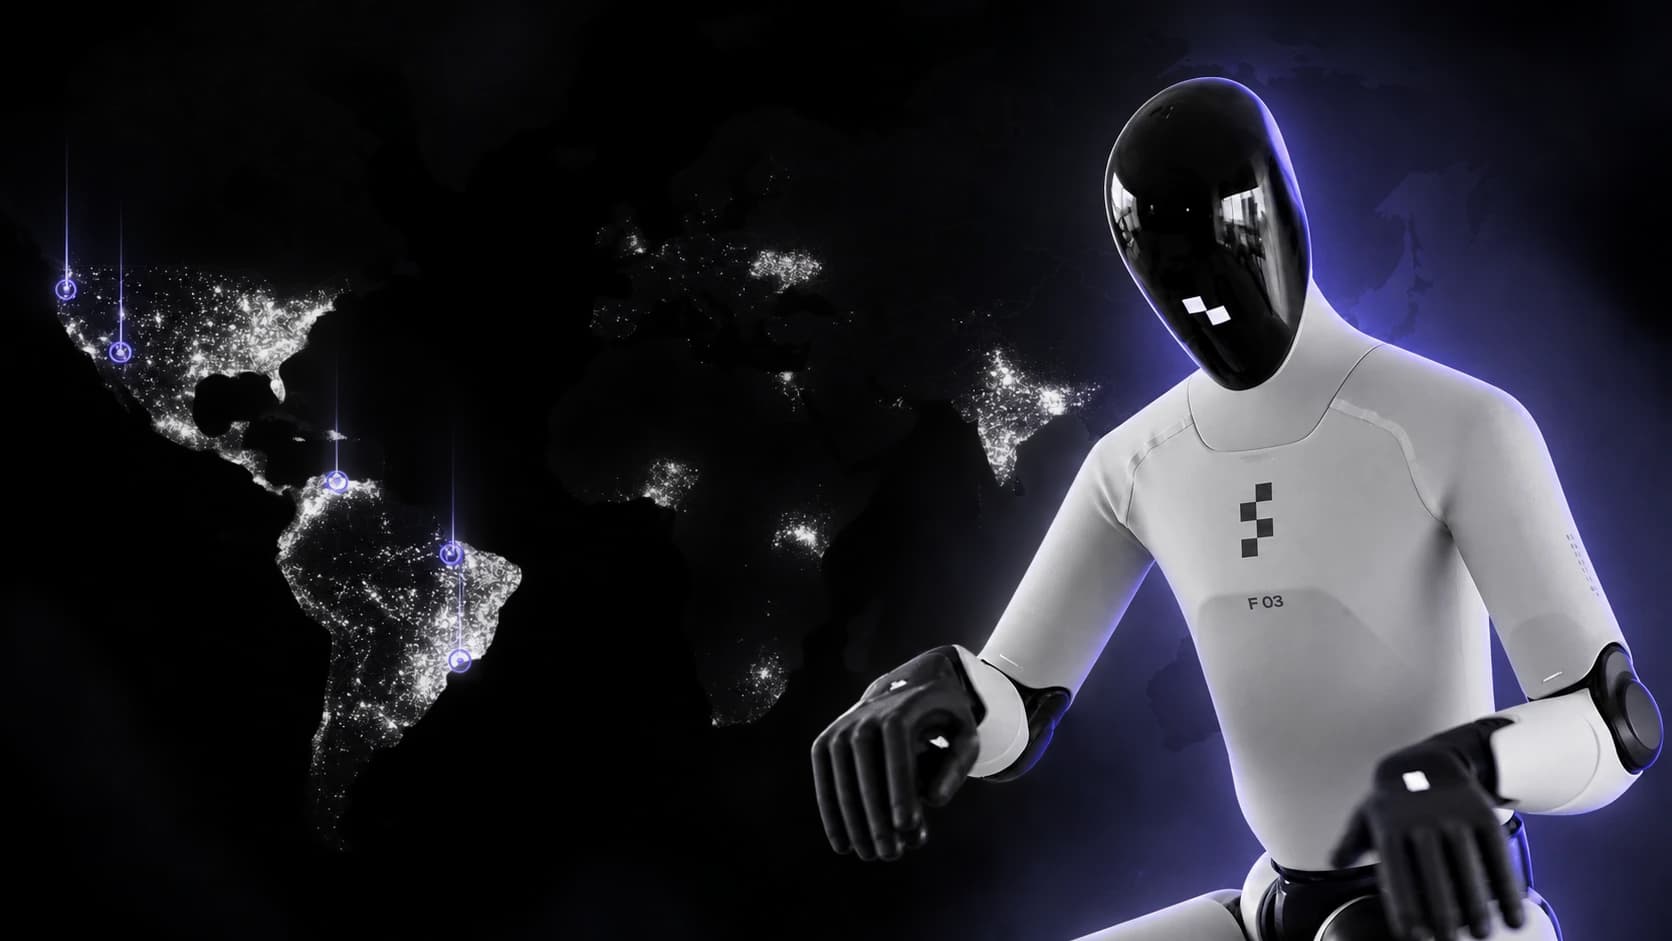
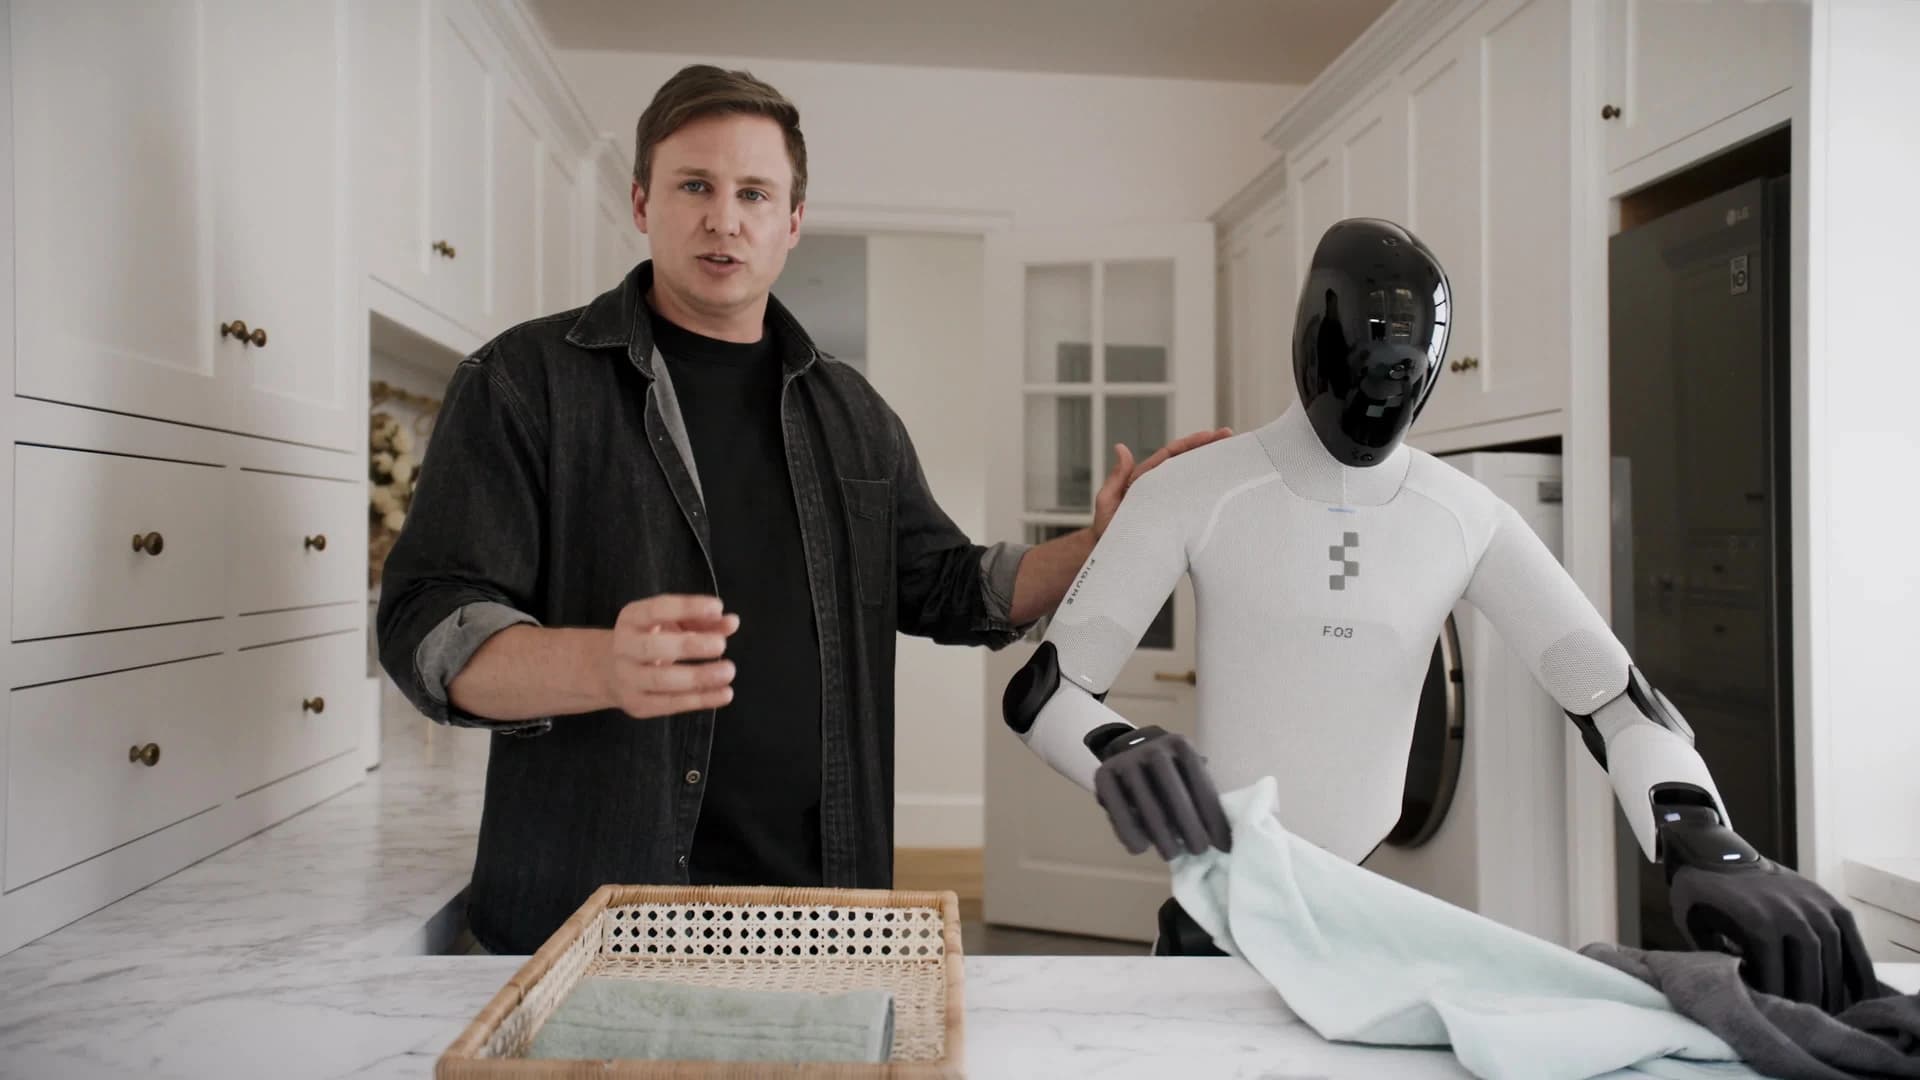
Figure CEO Brett Adcock believes scaling humanoid robots will eventually require hundreds of billions of dollars—and more data and compute than large language models.
In a September 22 post on X, Adcock shared a video excerpt posted by Humanoids Daily from his recent RoboStrategy interview and expanded on the argument behind his four stages of humanoid development.
He separates the hardware and whole-body AI engineering needed to make a robot work from the subsequent challenge of expanding its intelligence and production. His forecast concerns the latter stages; the post gives neither a spending timetable nor a Figure-specific budget.
What money can—and cannot—buy
The distinction builds on the framework in our original interview coverage. Adcock’s first chapter is capable hardware: a machine that meets the necessary requirements for speed, torque, dexterity, runtime, weight and cost. The second is an AI control architecture that can translate observations and instructions into sustained physical work.
The weekly humanoid robotics briefing
One email a week: the launches, funding and research that mattered, with context from Humanoids Daily.
Read recent issuesIn the interview, he argued that those problems require prolonged engineering effort. Giving an inexperienced team an enormous budget would not automatically produce a working humanoid, any more than it would guarantee a successful orbital rocket.
The third chapter is expanding what the robot can do reliably. Adcock’s thesis is that, once the architecture works, investment in training data and compute can translate into a wider range of successful behaviors. Manufacturing then needs to grow alongside that usefulness.
That sequencing does not mean postponing production engineering until the AI is finished. The commercial argument is that building large numbers of machines only makes sense when their capabilities justify customers buying them.
A bigger data bet
The new post makes the scale of Adcock’s expectations explicit. He predicts that humanoids’ requirements for training data and computation will surpass those of LLMs, but supplies no quantitative comparison to establish that forecast.
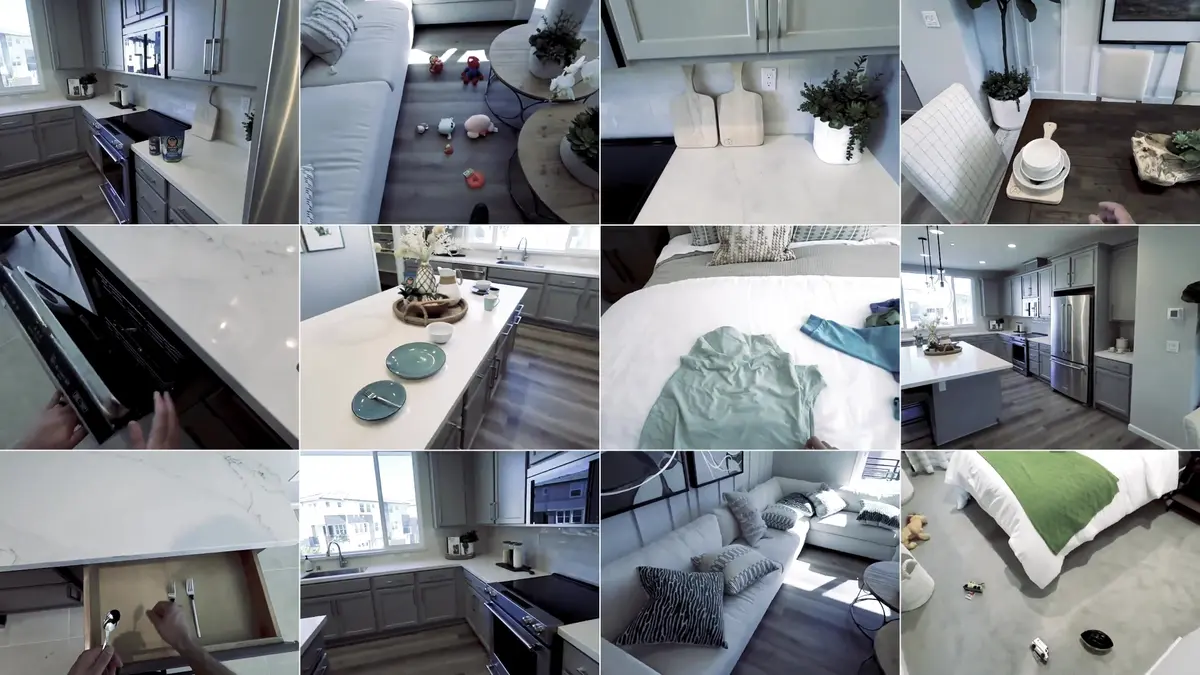
Figure’s own response to the data challenge is Index, its project to collect recordings of people performing physical tasks. During the RoboStrategy interview, Adcock said Figure initially tried purchasing data from outside providers, found the quality insufficient for its needs and built its own collection operation. He did not identify those vendors.
His explanation emphasized the suitability of the recordings as well as their volume: the sensors, the relationship between human demonstrations and robot behavior, and the work of cleaning and checking the data. Spending more on collection is therefore only useful if the resulting material helps the robot learn.
That is also the condition behind his broader scaling thesis. In the interview, Adcock described Figure as being near the beginning of the intelligence-scaling stage and presented Helix 2.5 as an early way to measure how additional data changes performance. He acknowledged that the release had not yet achieved his wider ambition for long-duration autonomous work in arbitrary homes.
The question for future releases is whether that improvement continues across more tasks, environments and longer periods of operation. Adcock’s latest post raises the size of the bet; the evidence will come from what the robots can consistently do.
Disclosure: RoboStrategy, which hosted the original interview, is a sponsor of Humanoids Daily. Adcock’s post embeds the interview excerpt shared by Humanoids Daily.
Share this article
Read next
- Published on
- Reading time
- 3 min read
Foxconn to Deploy NVIDIA-Powered Humanoid Robots in Houston AI Server Plant
- Published on
- Reading time
- 3 min read
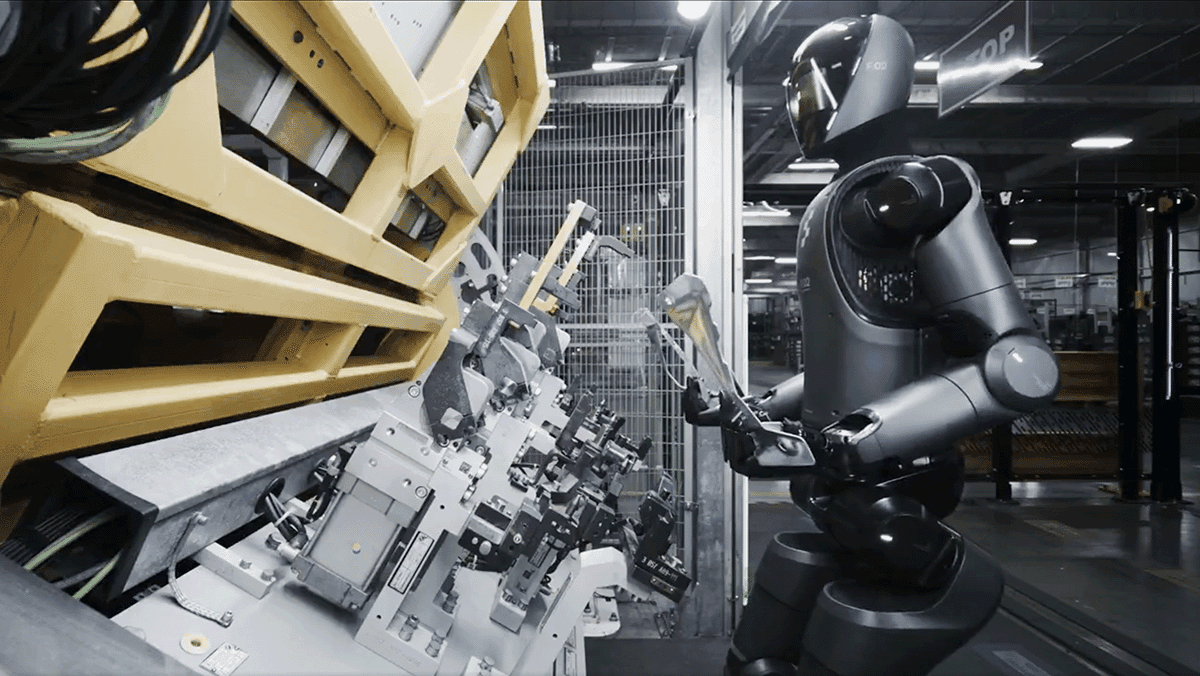
Figure Claims Humanoid Robot Has Worked Five Months on BMW Production Line
- Published on
- Reading time
- 6 min read
Meta AI Chief Yann LeCun Claims Humanoid Firms "Have No Idea" How to Build Generally Useful AI
- Published on
- Reading time
- 4 min read
Figure Launches 'Project Go-Big' to Train Humanoid Robots on Human Video Data
- Published on
- Reading time
- 4 min read
Figure's 'Most Boring Video' is a 60-Minute Statement on Humanoid Endurance
- Published on
- Reading time
- 4 min read
Figure CEO on Scaling Humanoids: 'You Can't Code Your Way Out of This Problem'
The weekly humanoid robotics briefing
One email a week: the launches, funding and research that mattered, with context from Humanoids Daily.
Read recent issues